Embodied AI
Intelligence,
entering the physical world.
The last decade taught machines to read and write. The next will teach them to act: to grasp, walk, drive and work. That intelligence is trained on human demonstration and human judgment. It is exactly what we do.
The shift
AI is leaving the screen.
Language models live in text. Embodied models live in the world, and the world does not come pre-labeled. Every physical skill a machine learns traces back to a person who demonstrated it, or judged it.
The last decade
Digital intelligence
Trained on a web already written by humans. Data was abundant, static and safe to get wrong: a bad answer is just a bad answer.
The next decade
Embodied intelligence
Trained on demonstrations that must be generated, sensor streams that must be aligned, and actions that must be judged for safety. Data is scarce, physical, and expensive to get wrong.
Tap a point to see the data behind it
What embodied AI runs on
The human work beneath every physical action.
Six workstreams that turn robots, humanoids and autonomous machines from simulations into systems that work in the real world.
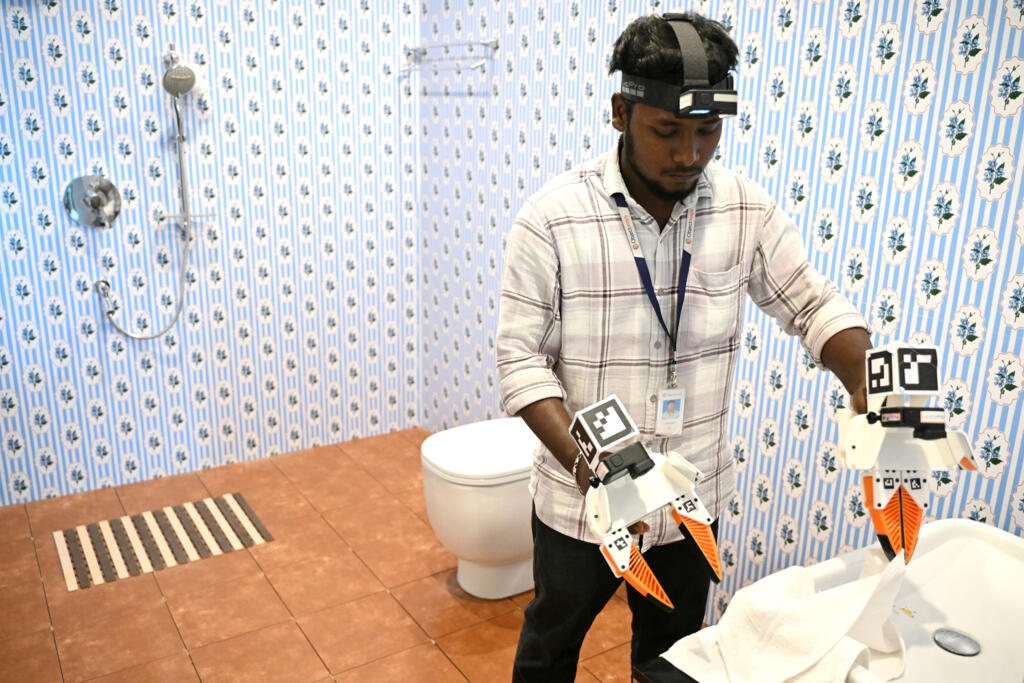
Teleoperation & demonstration
Trained operators drive robot arms, grippers and humanoids to generate the demonstration trajectories that imitation-learning policies are built on. Clean, repeatable, human-guided motion: the fuel of modern robot learning.
Multimodal sensor fusion
Aligning and labeling vision, depth, force, audio and proprioception into a single time-synchronized stream. Embodied models only learn to act when the senses agree: we make them agree.
3D, LiDAR & spatial labeling
Point-cloud segmentation, cuboids, occupancy grids and scene graphs that give a machine a sense of space: where things are, how far, and whether it can pass. The geometry layer beneath every physical action.
Action & affordance annotation
Segmenting what can be grasped, pushed, opened or avoided, and labeling the sequence of sub-actions inside a task. Affordances turn a pile of pixels into a set of things a robot can actually do.
Sim-to-real validation
Reviewing simulated policies against real-world behavior, flagging where the model and the physics diverge. The bridge that keeps a policy trained in simulation from breaking the moment it meets a real floor.
Physical-world safety & red-teaming
Stress-testing robot actions before they touch the world: near-miss labeling, unsafe-behavior review and human-preference judgments on which action is safest. Because in embodied AI, a mistake is not a bad sentence. It is a collision.
Watch
The physical-AI shift, on film.
How the world's newsrooms are covering AI factories, robotics and the human work behind intelligent machines.
The AI factory: the rewiring of India's tech industry
How AI and robotics are challenging business
The workers training the AI behind tomorrow’s machines
The real bottleneck
Compute is scaling. Robots are shipping. The scarce input is human demonstration.
You cannot download a robot picking up a cup ten thousand times in ten thousand kitchens. Someone has to generate it, align it, review it and judge whether it was safe. Embodied AI is fundamentally a human-in-the-loop problem, and that is the layer we operate.
Why HSV · why Nepal
Built for the physical-data era.
Embodied AI needs people, environments and power at scale. Nepal has all three, and we have organized them into an operation.
A workforce built for demonstration
Embodied data is generated by people, not scraped from the web. Nepal's young, educated, English-proficient workforce is trained to teleoperate, demonstrate and judge, at a scale and cost the frontier can't reach elsewhere.
Real, varied physical environments
From dense city streets to terraced farmland to the high Himalaya, we sit inside some of the most varied terrain on earth, the kind of environmental diversity embodied models need and rarely get.
Clean power, honest cost
Robot learning is compute-hungry. We run on abundant Himalayan hydropower and deliver operations at a cost structure that makes large-scale, human-in-the-loop embodied programs viable.
One partner for the whole loop
Collection, teleoperation, annotation, review, sim-to-real validation and safety: under one roof, one NDA and one quality standard. You brief once; the physical-data loop runs end to end.
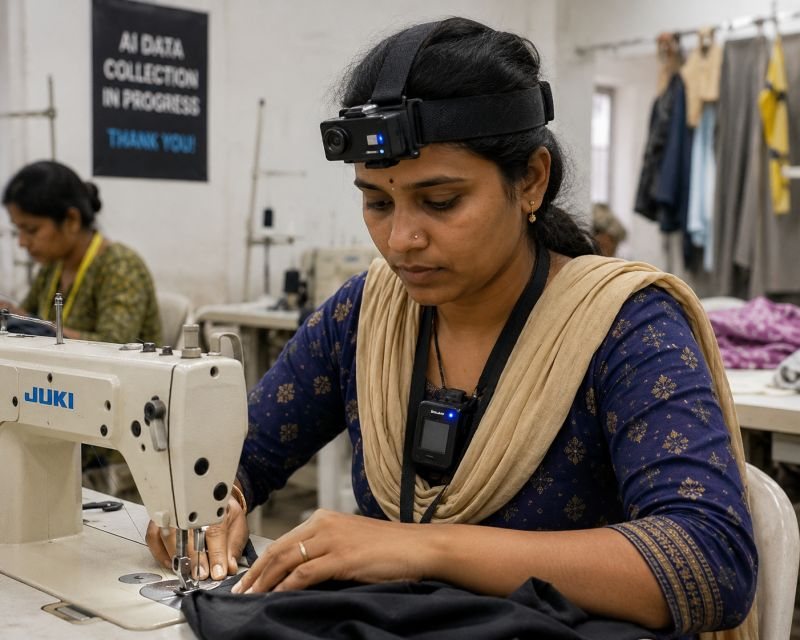
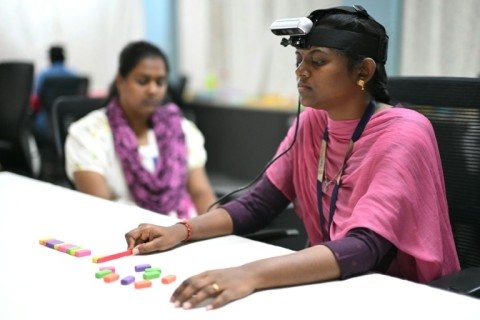
Inside the work
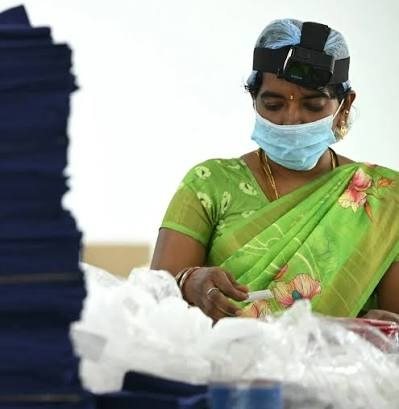
Where embodied data gets made.
From teleoperation stations to sensor rigs and safety review: the physical-data loop, on our floor.
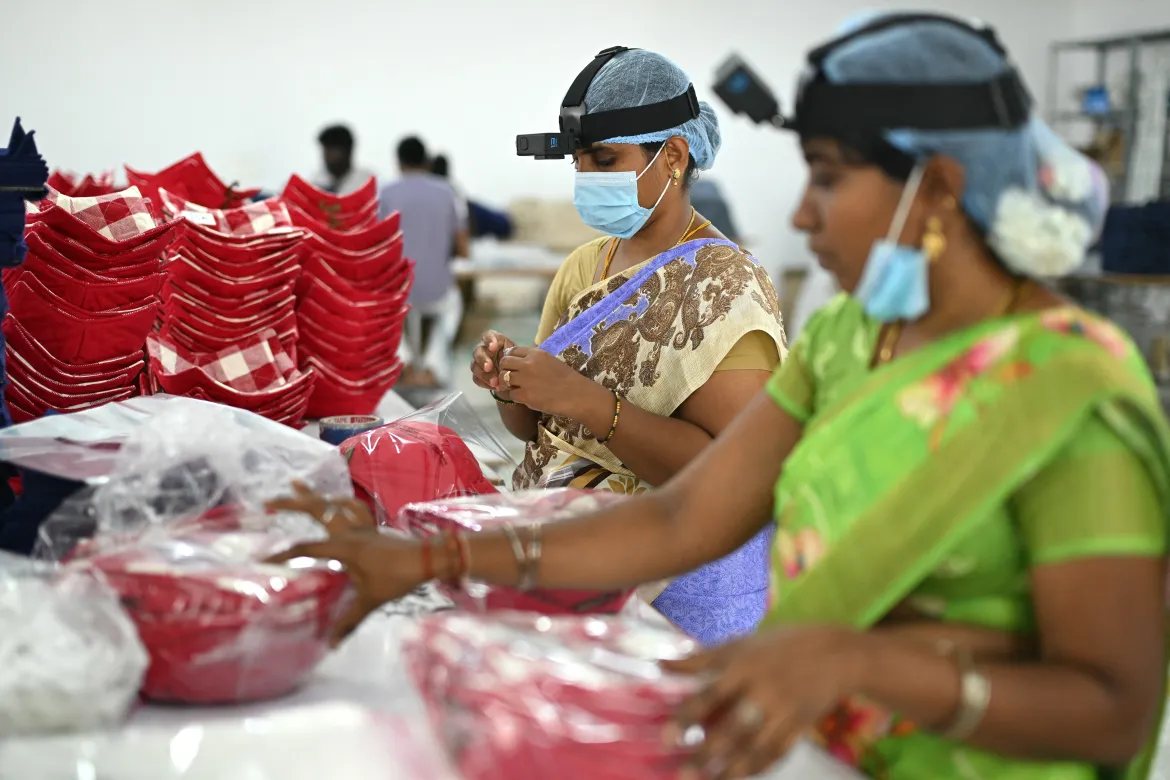
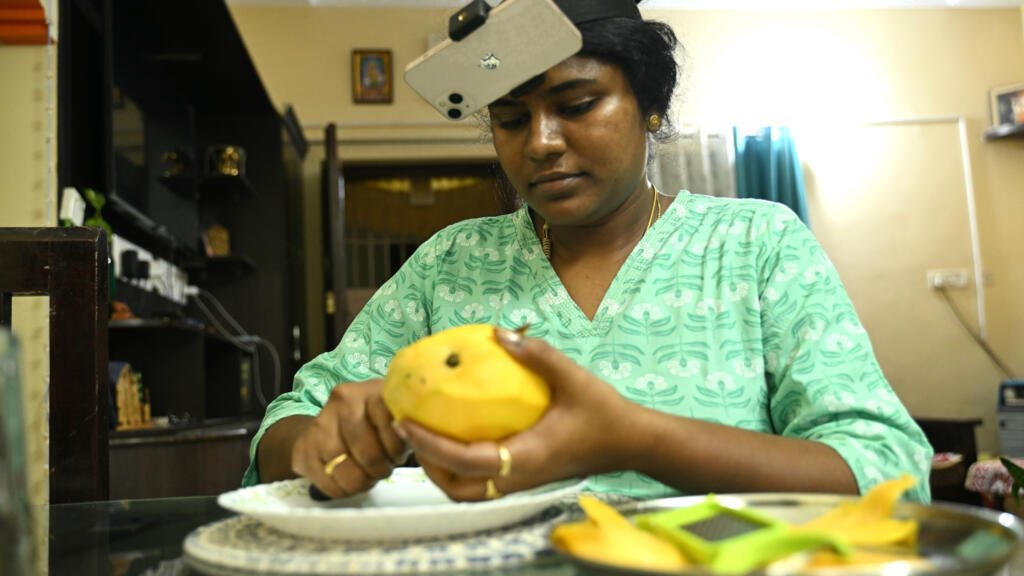
How we deliver
Physical data you can trust.
Trained, not crowdsourced
Every operator is trained against your protocol and cleared through trial tasks before touching live hardware or data.
Double review, every batch
Named operators, traceable trajectories, second-pass QA on every delivery. Nothing ships on a single set of eyes.
Secure by default
Isolated workspaces under NDA. Your hardware profiles, environments and demonstrations stay inside our platform.
Delivered to spec
Structured schemas, real-time dashboards and clean handoff to your training pipeline: data you can drop straight into a policy.
Build the physical layer with us
The next AI will move. Help it learn how.
Whether you are training robot policies or building an embodied-data team, one conversation starts the loop.